1. Introduction
Manufacturing is increasingly characterised by shorter product life cycles, demand volatility, customer-specific variants, pressure for productivity improvement and the need to reduce waste and unsafe manual work. These conditions have accelerated interest in agile production systems capable of rapidly adapting to changes in product specifications, volumes and production sequences (Hormozi, 2001; Potdar et al., 2017; Lokhande & Sarode, 2020; Kumar et al., 2021). Industrial robots are central to this transition; nevertheless, many production tasks, particularly in final assembly and high-variation environments, continue to rely on manual labour because automation remains costly, difficult to reconfigure and challenging to integrate in small- and medium-sized enterprise (SME) contexts (International Federation of Robotics, 2020, 2025; Sanneman et al., 2021).
Conventional industrial robots have historically been optimised for repeatability in structured environments. They can deliver high precision and throughput when tasks are stable and well specified, but they are less suitable for variable, low-volume or frequently reconfigured production lines. In many factories, a robot still performs a narrow set of tasks and requires specialised programming, fixed tooling, dedicated safety arrangements and significant integration effort whenever production changes (Sanneman et al., 2021; Arents & Greitans, 2022). These limitations create a gap between the promises of flexible automation and the practical requirements of agile manufacturing.
AI-powered versatile robotics addresses this gap by combining robotic hardware with advanced perception, task-and-motion planning, learning-based control, adaptive manipulation and human-robot collaboration capabilities. Such systems aim to increase autonomy and flexibility while allowing robots to be repurposed across tasks and production contexts (Wan et al., 2021; Arents & Greitans, 2022; Othman & Yang, 2023). However, the move from task-specific automation to AI-powered versatility introduces new implementation risks. A robotic system that is adaptive and data-driven must also be reliable, maintainable, interpretable, safe, secure, interoperable and acceptable to the workforce that will operate alongside it (Evjemo et al., 2020; Sanneman et al., 2021; Passalacqua et al., 2025).
The sociotechnical nature of the challenge is therefore central. Technical readiness alone does not guarantee adoption. Shop-floor workers may resist robotics if deployment is associated with job loss, constant monitoring, diminished autonomy or insufficient training (Evjemo et al., 2020; Dhanda et al., 2025; Passalacqua et al., 2025). Managers may prioritise productivity and return on investment, while engineers may prioritise reliability, integration feasibility and maintainability. Ethics experts may emphasise privacy, accountability, explainability, fairness and human oversight (Hickman & Petrin, 2021). A publication-quality assessment of versatile robotics for agile production must therefore integrate technical, organisational and ethical dimensions rather than treating them as separate domains (Michalec et al., 2021; Brèque et al., 2021).
This paper contributes such an integrated assessment through the Horizon Europe AGIMUS project, which develops open-source solutions for agile production using AI-powered versatile robotics. The study does not report the final technical performance of the AGIMUS robotic system; rather, it establishes and empirically substantiates the requirement baseline needed to guide responsible design and deployment. The research combines desk research, expert interviews, industrial case-study analysis and a stakeholder survey to answer three research questions: (RQ1) What technical and ethical needs must be addressed for AI-powered versatile robotics to support agile production? (RQ2) Which barriers, challenges, drivers and enablers are most relevant for adoption in industrial contexts? (RQ3) Which workforce concerns and acceptance mechanisms should be prioritised to support trustworthy deployment?
The paper offers four contributions. First, it consolidates fragmented technical and ethical requirements into a single baseline framework. Second, it refines and substantiates the framework through expert and industrial case-study evidence. Third, it provides quantitative prioritisation from 180 European stakeholders across managers, researchers/engineers, and operators/workers. Fourth, it translates the findings into design, implementation and policy implications for human-centric agile manufacturing ecosystems.
The quantitative dataset was collected in March 2023. Since then, the industrial AI and robotics landscape has changed substantially: AI management-system standardisation advanced, industrial robot safety standards were updated, and recent Industry 5.0 literature placed stronger emphasis on human-centricity, trustworthy AI, personalisation and workforce well-being (Ahangar et al., 2025; Bucci et al., 2025; Dhanda et al., 2025; Ibarguren et al., 2025). Consequently, this paper does not present the survey as a current market forecast. Instead, it frames the dataset as a pre-AI-Act baseline that remains valuable for understanding which concerns were already salient before the most recent governance and technology developments.
2. Materials and methods
The study adopted a mixed-methods design, as illustrated in
Figure 1, because the research problem required both qualitative depth and quantitative prioritisation. Desk research was used to identify candidate categories from literature and strategic roadmaps; semi-structured interviews were used to refine and assess the relevance of the categories with technical and ethics experts; industrial case studies were used to ground the analysis in realistic production settings; and the survey was used to quantify stakeholder perceptions across a broader sample. This combination was selected to reduce the risk of relying only on desk-based assumptions or only on self-reported survey priorities and is consistent with established mixed-methods research logic (Johnson et al., 2007).
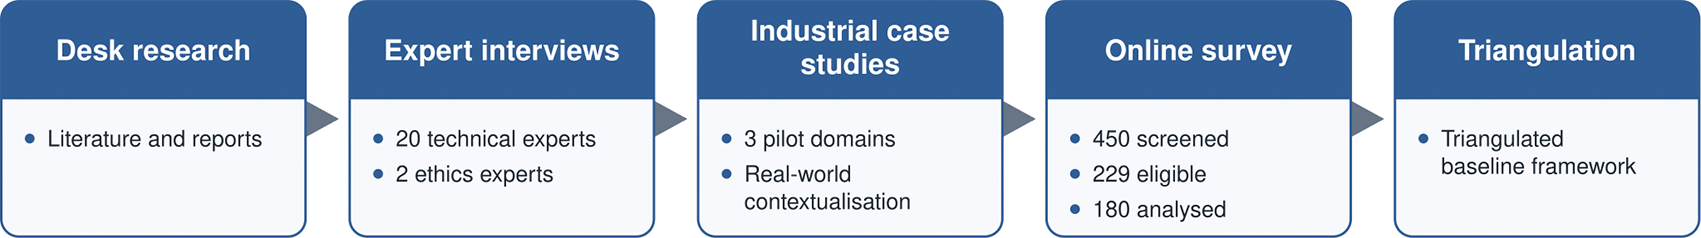
Figure 1. Mixed-methods design for deriving and prioritising the AI-powered versatile-robotics baseline framework.
2.1 Desk research
The desk research reviewed scientific publications, European industrial roadmaps, policy documents and reports related to agile manufacturing, industrial robotics, AI-driven manufacturing systems, collaborative robotics, trustworthy AI and smart production (SRIDA, 2020; Arents & Greitans, 2022; Othman & Yang, 2023). The objective was not to conduct a systematic review in the narrow bibliometric sense, but to establish a structured analytical baseline. The search focused on recurrent industrial requirements and adoption factors relevant to versatile robotics. The resulting categories were grouped as technical needs, ethical needs, challenges, barriers, drivers, and enablers. This typology was used consistently in the following empirical stages.
2.2 Semi-structured interviews
Semi-structured interviews were conducted with 20 technical and industrial stakeholders from the AGIMUS consortium, the AGIMUS Industrial Advisory Board and wider professional networks. The sample included managers, researchers, engineers, and operators/workers. Two additional interviews were conducted with external experts in AI and robotics ethics. In total, the qualitative interview evidence therefore comprised 22 expert interviews. The interviews aimed to assess the relevance and completeness of the desk-research categories, identify omitted dimensions and refine the terminology used for the survey instrument.
Interviewers used a common interview guideline to ensure comparability while allowing respondents to elaborate on context-specific issues. The interview guideline is publicly available as extended data on Zenodo (https://doi.org/10.5281/zenodo.10058708). Interviews were conducted by interviewers with relevant linguistic and technical background, including French, Czech, Greek and Spanish interviewers, to support communication in interviewees’ preferred languages. This design choice was methodologically important because robotics adoption is operationally and culturally situated: reducing linguistic friction helps elicit more specific and reliable reflections on production realities, risks and organisational constraints.
2.3 Industrial case-studies
The case-study component examined industrial pilot settings connected to AGIMUS. The purpose was not to generalise statistically from a small number of cases, but to test whether the emerging framework reflected realistic industrial constraints, in line with the use of case studies for contextualised inquiry and exploratory understanding (Flyvbjerg, 2006; Priya, 2021). The case-study domains covered aircraft and satellite manufacturing, lift manufacturing and packaging manufacturing. Across these domains, the analysis considered activities such as deburring, solar-array assembly, gluing reinforcement parts, floor-covering assembly, gluing cardboard sides and inserting small plastic components into packaging materials.
The case studies were used to identify practical requirements that may not be sufficiently visible in abstract literature, including accuracy demands, maintainability constraints, safety requirements, non-technical risks and technology-acceptance issues.
2.4 Online survey and sampling strategy
The online survey was deployed through Prolific between 27 and 31 March 2023. Prolific was selected because it allows structured participant screening, participant privacy, efficient recruitment and comparatively strong data quality controls for online research samples (Palan & Schitter, 2018; Peer et al., 2022). The recruitment strategy was appropriate for exploratory sociotechnical research requiring access to respondents familiar with agile production and robotics across several European countries. However, it cannot replace a statistically representative sectoral survey of European manufacturing companies. Known advantages and risks of crowdsourced or online-panel research, including access, efficiency, data quality, fraud risk and sample-validity limitations, were therefore considered when screening and interpreting the responses (Behrend et al., 2011; Mason & Suri, 2012; Smith et al., 2015; Porter et al., 2018; Xia, 2022).
Participant selection involved two sequential selection and quality-control stages. First, 450 respondents completed a screening pre-survey used to assess eligibility for participation in the main survey. This screening stage was designed solely to determine eligibility and did not constitute pilot testing of the main questionnaire. The pre-survey comprised four screening questions designed to assess respondents’ familiarity with agile production and versatile robotics and to identify responses indicating assumptions inconsistent with the predefined technological-maturity criteria used for participant screening. Participants were first asked whether they had a good understanding of (i) agile production and (ii) versatile, collaborative robotic solutions for agile production. Both questions used a binary Yes/No response.
Respondents were then presented with three indicative generations of versatile robotics: first-generation systems, in which workers perform tasks and robotic systems enhance their efficiency; second-generation systems, in which robotic systems perform tasks under worker supervision; and third-generation systems, in which robotic systems operate autonomously and perform tasks entirely on their own. They were asked which generation they considered most common at present and how soon they expected third-generation versatile robotics to become the norm.
Participants were excluded from the main survey if they (i) answered “No” to both familiarity questions, (ii) identified third-generation robotics as the generation currently most common, or (iii) stated that third-generation robotics was already the norm. These criteria were intended to increase the likelihood that the main survey was completed by respondents with sufficient familiarity with the subject and with responses consistent with the technological-maturity assumptions defined for the screening process. Of the 450 respondents screened, 229 met these criteria and were admitted to the main survey.
Second, completed main-survey responses were subjected to data quality screening before analysis. Responses were excluded where response patterns indicated potential data quality problems, including conflicting answers and unusually fast completion times. Following these checks, 49 of the 229 main-survey responses were excluded and 180 valid responses were retained for quantitative analysis. The resulting recruitment and screening process therefore comprised an initial pool of 450 screening pre-survey respondents, 229 respondents eligible for the main survey, and a final analytical sample of 180 respondents after data quality screening, as summarised in
Table 1.
Table 1. Survey recruitment, screening and retained sample.
| Indicator | Value | Methodological role |
|---|
| Screening pre-survey participants | 450 | Large screening pool used to reduce the risk of relying on respondents with insufficient familiarity with the topic. |
| Eligible for main survey | 229 | Eligibility criteria increased topical relevance before the full questionnaire. |
| Excluded after data quality screening | 49 | Responses excluded because of conflicting response patterns or unusually fast completion times. |
| Analysed responses | 180 | Valid responses retained for quantitative analysis after eligibility and data quality screening. |
| Stakeholder roles | Managers 29%
Researchers/engineers 41%
Operators/workers 30% | The role split enables comparison between strategic, technical and shop-floor perspectives. |
| European coverage | 16 countries | The sample supports European-level exploratory insights, while not claiming full representativeness. |
Among the 180 retained respondents, all reported having a good understanding of agile production, while 88.3% reported a good understanding of versatile robotics. The final sample represented 16 European countries, with the largest shares from Poland (20.6%), Spain (13.9%), Italy (12.2%), Portugal (8.9%), Germany (8.9%) and Hungary (7.2%). The sample was 75% male and 25% female. It included managers (29%), researchers/engineers (41%), and operators/workers (30%). Most respondents worked in industry (82%), followed by start-ups (9%), governance (4%), academia (3%), and other sectors (2%).
Written informed consent was obtained from all interviewees prior to the interviews. Survey participants were recruited through Prolific and voluntarily opted into the study after reviewing the study information provided through the platform.
2.5 Temporal scope and interpretation of the survey data
The temporal scope of the survey is central to the interpretation of the results. Because the data were collected in March 2023, they should be read as a baseline snapshot of stakeholder perceptions before several major developments in European AI governance and industrial robotics standardisation. This does not invalidate the dataset, but it changes its evidentiary role. The results are most robust when used to identify persistent sociotechnical concerns, design requirements and acceptance mechanisms; they should not be used as a stand-alone indicator of current 2026 market readiness or present-day willingness to adopt AI-powered robotics without updated validation (Ahangar et al., 2025; Dhanda et al., 2025).
2.6 Measures and quantitative analysis
Survey items used five-point Likert-type response scales. For importance ratings, responses ranged from 1 = not important to 5 = extremely important. For agreement questions, responses ranged from 1 = strongly disagree to 5 = strongly agree. Weighted mean values (WMVs) were calculated to compare the perceived importance of technical needs, challenges, barriers, drivers and enablers across all respondents and across stakeholder groups. For an examined item, the overall WMV was calculated as:
(1)
where:
•
is the number of respondents assigning score “
” to the examined aspect;
•
is the total number of respondents, i.e., 180.
For stakeholder group “x”, the group-specific WMV was calculated as:
(2)
where:
•
is the number of respondents in group “
” assigning score “
” to the examined aspect;
•
the total number of respondents in that group.
The WMV approach was used for descriptive relative prioritisation rather than causal inference. Stakeholder-group WMVs represent independent group-specific scores and are not additive.
Ethical needs were not ranked using the same classification method. This methodological choice was deliberate: ethical requirements such as privacy, fairness, accountability and human oversight are normative safeguards and should not be deprioritised solely because one group rates them lower. Instead, ethical needs were analysed qualitatively and through agreement/difficulty patterns, preserving their role as baseline design requirements in line with trustworthy-AI principles (Hickman & Petrin, 2021).
The survey questionnaire was developed specifically for this exploratory study on the basis of the desk-research framework and was further refined through the expert interviews and industrial case-study analysis described in Sections 2.2 and 2.3. The questionnaire was not subjected to a separate formal validation study. The expert interviews and industrial case-study analysis provided expert review of the relevance, completeness and terminology of the proposed survey dimensions. No separate formal face-validity test, preliminary pilot study or reliability testing was conducted before deployment. The 450-participant screening pre-survey described in Section 2.4 was used exclusively to assess participant eligibility and did not constitute pilot testing of the main questionnaire. The full questionnaire is publicly available through the AGIMUS survey dataset on Zenodo (https://doi.org/10.5281/zenodo.10058980).
3. Results
3.1 Desk research framework
Desk research identified a preliminary framework consisting of technical needs, ethical needs, challenges, barriers, drivers and enablers. These categories were defined to avoid conceptual overlap. Needs refer to core requirements that versatile robotics should satisfy; challenges are complex issues requiring strategic action; barriers are concrete obstacles that hinder fulfilment of needs; drivers are factors that motivate adoption; and enablers are resources, tools, standards or support conditions that facilitate implementation (SRIDA, 2020; Kumar et al., 2021; Wan et al., 2021).
The technical needs identified through the desk research were adaptability, reliability, scalability, increased accuracy, maintainability, and interoperability/interconnectivity, reflecting recurring concerns in smart manufacturing and industrial robotics research (Rossmeissl et al., 2019; Sanneman et al., 2021; Arents & Greitans, 2022; Sun et al., 2023). The ethical needs were safety, privacy, transparency, accountability, and societal/environmental well-being, reflecting several core trustworthy-AI considerations (Floridi et al., 2022). The initial ethical-needs baseline was not intended to reproduce the seven requirements for Trustworthy AI defined by the High-Level Expert Group on Artificial Intelligence (AI HLEG) (High-Level Expert Group on Artificial Intelligence, 2019) established by the European Commission. Rather, it reflected those ethical requirements that emerged most consistently from the reviewed literature on industrial robotics and smart manufacturing.
The main challenges were exploitation of big data, human-robot collaboration and technology acceptance (Evjemo et al., 2020; Wan et al., 2021). The main barriers were unclear scope or value proposition, low technology readiness level and investment/maintenance costs (Kumar et al., 2021; Sanneman et al., 2021). The drivers included competitiveness, customer satisfaction, return on investment, waste reduction, reduced stress, cost reduction, increased productivity and improved product quality (Hormozi, 2001; Phuyal et al., 2020). The enablers included 5G communications, simulation techniques, ease of use, open-source software, IT systems, standardisation and policy/regulations (Ng et al., 2016; Potdar et al., 2017; Shurdi et al., 2021). The resulting initial desk-research framework is summarised in
Table 2.
Table 2. Initial baseline framework derived from desk research.
| Technical needs | Ethical needs |
|---|
– Adaptability
– Reliability
– Scalability
– Increased accuracy
– Maintainability
– Interoperability & interconnectivity | – Safety
– Privacy
– Transparency
– Accountability
– Societal & Environmental well-being
|
| Challenges
| Barriers
| Drivers
| Enablers
|
– Exploitation
of big data
– Human-Robot collaboration
– Technology acceptance | – Unclear scope or value proposition
– Low TRL
– Investment & Maintenance costs | – Competitiveness
– Customer satisfaction
– Return On Investment
– Waste reduction
– Reduced stress
– Cost reduction
– Increased productivity
– Improved product quality | – 5G communications
– Simulation techniques
– Ease of use
– Open-source software
– IT systems
– Standardisation
– Policy & Regulations |
The initial framework is justified by the dual nature of agile production. On the one hand, robotic systems must meet strict engineering requirements such as reliability, accuracy and interoperability; on the other hand, they are deployed in human work systems where privacy, safety, fairness and trust can influence acceptance (Brèque et al., 2021; Othman & Yang, 2023). Treating these dimensions jointly is necessary because a technically advanced robotic system that is perceived as unsafe, opaque or threatening to jobs may fail to be adopted (Evjemo et al., 2020; Dhanda et al., 2025; Passalacqua et al., 2025).
3.2 Qualitative refinement through interviews and case studies
The interviews confirmed the relevance of the desk-research framework while also revealing dimensions that had been insufficiently captured in the initial literature-based baseline. In particular, the ethics interviews enabled a more systematic alignment of the framework with the seven requirements for Trustworthy AI defined by the AI HLEG. Experts emphasised that adaptable robotic systems can help workers shift between tasks, support reconfigurable lines and reduce repetitive or ergonomically difficult activities. However, they also stressed that deployment must preserve human oversight, minimise intrusive data collection and provide understandable explanations of what the robot does, why it does it and which data are required.
The ethics interviews led to a more precise formulation of ethical needs. Safety was expanded into technical robustness and safety, because industrial safety depends not only on compliance with physical safety measures but also on robust behaviour under real operating conditions and cyber-secure system operation. Privacy was expanded into privacy and data governance, because data collection, storage, access rights and secondary use are central concerns in AI-enabled production environments. Two further ethical dimensions were added: human agency and oversight, and diversity, non-discrimination and fairness, consistent with the seven requirements for Trustworthy AI. Their explicit inclusion in the refined framework therefore reflects evidence from the qualitative research while also addressing dimensions that were not sufficiently prominent in the initial desk-research synthesis.
The industrial case studies reinforced the importance of increased accuracy, reliability, maintainability and safety. They also highlighted drivers such as waste reduction, improved health and safety, reduced operator stress, cost reduction, increased productivity and improved product quality. Technology acceptance emerged as a cross-cutting challenge, particularly where workers may interpret robots as a threat to job stability or professional value. The final baseline framework resulting from this qualitative refinement is presented in
Table 3.
Table 3. Final baseline framework after qualitative refinement.
| Technical needs | Ethical needs |
|---|
– Adaptability
– Reliability
– Scalability
– Increased accuracy
– Maintainability
– Interoperability and interconnectivity | – Technical robustness and safety
– Human agency and oversight
– Privacy and data governance
– Transparency
– Accountability
– Societal and environmental well-being
– Diversity, non-discrimination and fairness |
| Challenges
| Barriers
| Drivers
| Enablers
|
– Exploitation
of big data
– Human-Robot collaboration
– Technology acceptance | – Unclear scope or value proposition
– Low TRL
– Investment and maintenance costs | – Competitiveness
– Customer satisfaction
– Return on investment
– Waste reduction
– Reduced stress
– Cost reduction
– Increased productivity
– Improved product quality | – 5G communications
– Simulation techniques
– Ease of use
– Open-source software
– IT systems
– Standardisation
– Policy and regulations |
The final framework should be interpreted as a requirement baseline rather than a static checklist. Its value lies in making explicit the conditions that must be considered before and during deployment. This is important for both research projects and industrial adopters: without such a baseline, technical development may optimise isolated robotic capabilities while under-addressing organisational, ethical and workforce conditions that influence uptake.
3.3 Quantitative prioritisation of needs, challenges, barriers, drivers and enablers
The survey results supported the relevance of the framework. All assessed technical needs, challenges, barriers, drivers, and enablers scored above the midpoint of the importance scale, indicating that stakeholders considered all assessed dimensions at least moderately important, as presented in
Figure 2.
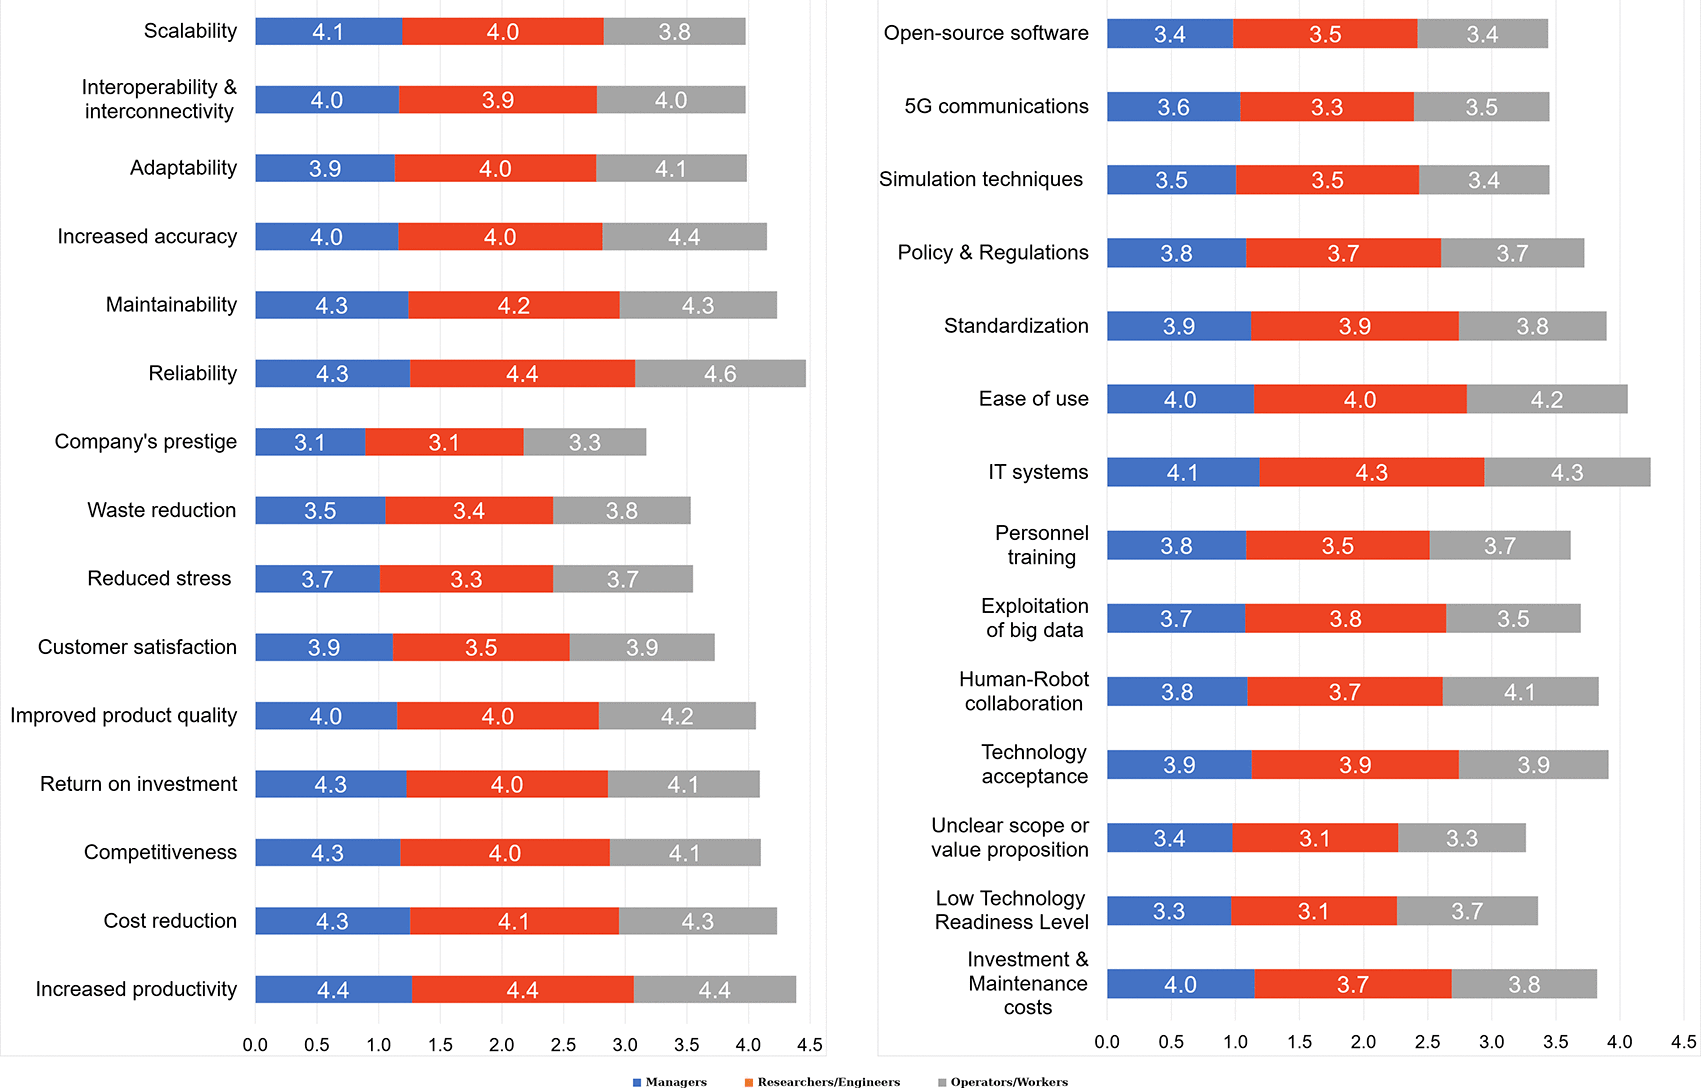
Figure 2. Weighted mean importance of adoption factors across stakeholder groups.
Importance Rating Scale: [1] Not important; [2] Slightly important; [3] Moderately important; [4] Very important; [5] Extremely important.
The three stakeholder-group weighted mean values shown for each item are independent scores on the same 1–5 importance scale and should not be interpreted cumulatively or as components of a total. The juxtaposed segments are used solely to facilitate compact visual comparison between stakeholder groups.
In addition to the dimensions retained in the final baseline framework, the survey instrument included two exploratory items: company prestige as a potential driver and personnel training as a potential implementation challenge. These items were included to capture adjacent organisational considerations that emerged during questionnaire development. They were retained in the quantitative analysis for completeness but were not carried forward as standalone dimensions in the final framework. Company prestige was considered less directly related to the operational adoption of versatile robotics than the retained economic and performance-related drivers, while personnel training was treated in the final synthesis primarily as a response to broader technology-acceptance and implementation challenges rather than as a distinct challenge in itself.
The ranking revealed clear priorities. Reliability, maintainability, and increased accuracy received the highest values among technical needs. Increased productivity, cost reduction, competitiveness, and return on investment were among the strongest drivers. Technology acceptance and human-robot collaboration received the highest ratings among the assessed challenges, while investment and maintenance costs emerged as the most prominent barrier. IT systems and ease of use ranked highly among enablers, showing that deployment is perceived as an integration and usability challenge, not only a robotics-hardware challenge.
The practical justification of this result is direct: agile production environments have low tolerance for downtime, unreliable sensing, unplanned maintenance and unstable performance. A robotic system may be adaptable in principle, but reliable performance under production constraints and maintainability without excessive downtime or specialised intervention remain important conditions for industrial acceptance. This explains why reliability and maintainability are not merely engineering properties but adoption prerequisites (Sanneman et al., 2021; Arents & Greitans, 2022).
3.4 Perceived difficulty of meeting technical and ethical needs
Stakeholders were also asked to assess the perceived difficulty of fulfilling the 13 technical and ethical needs included in the refined framework.
Figure 3 presents the response distribution across the five-point agreement scale, allowing comparison of the relative difficulty associated with each need.
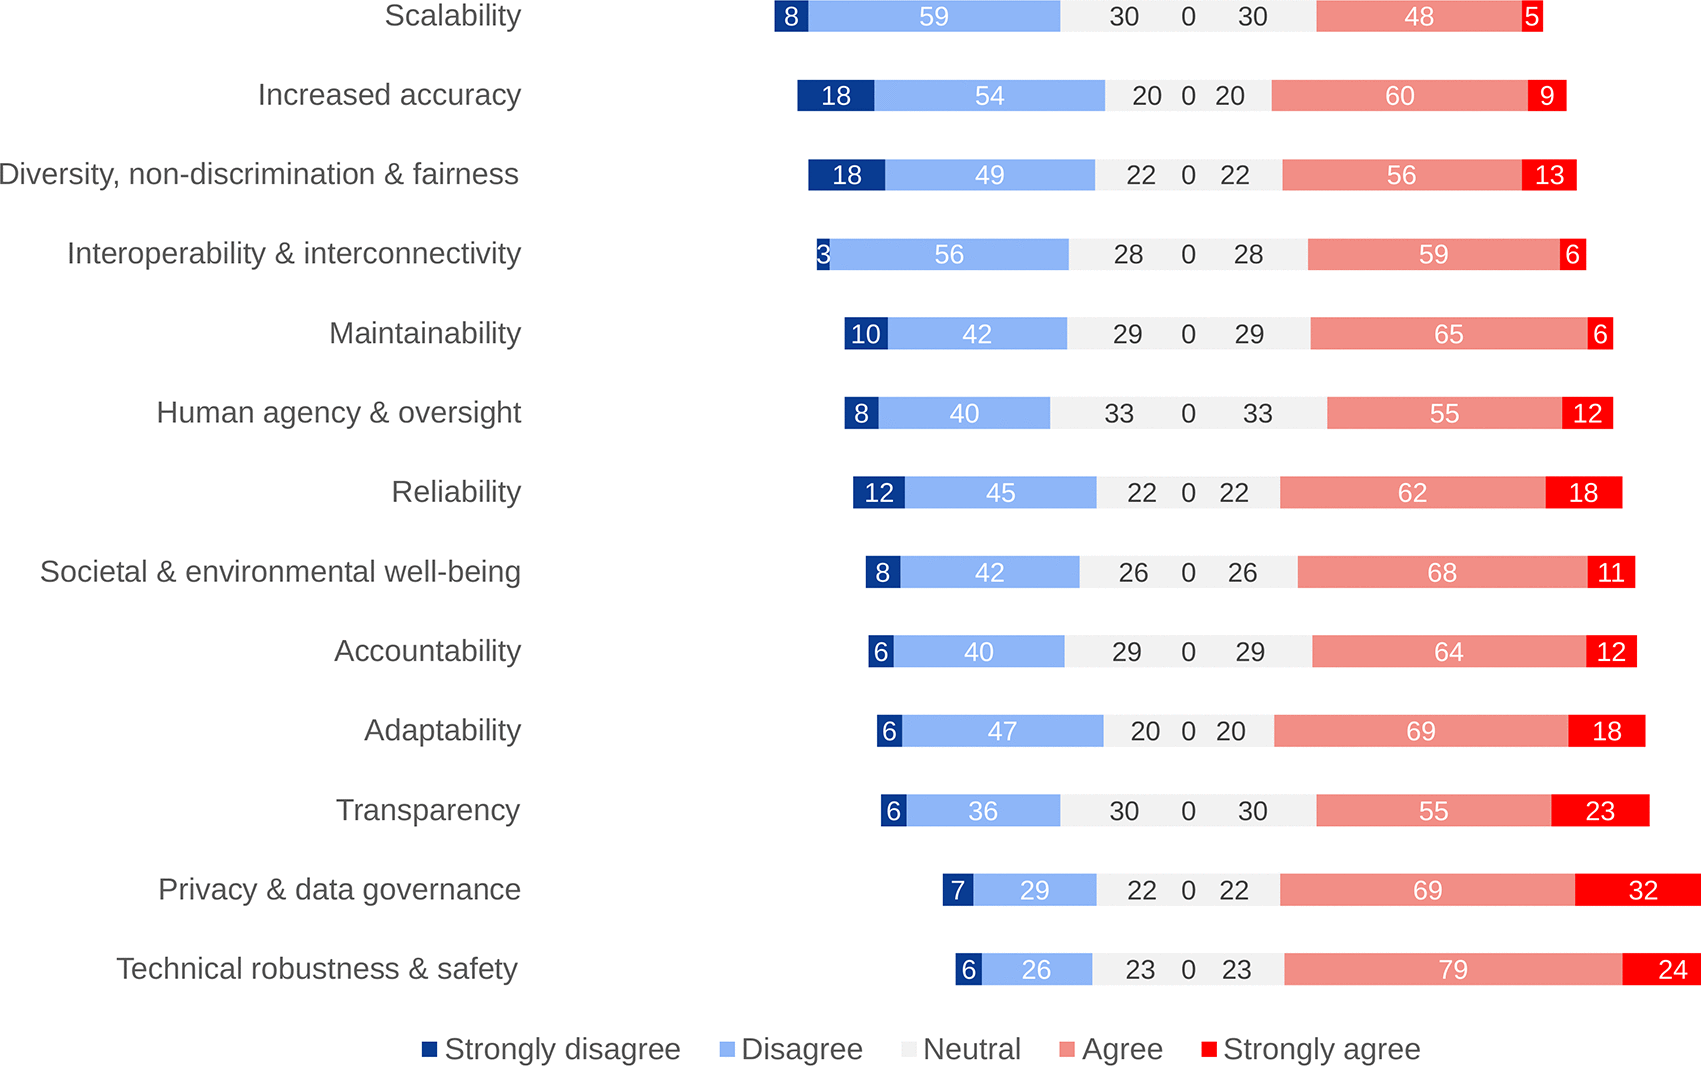
Figure 3. Perceived difficulty of meeting technical and ethical needs in versatile robotics.
Responses are shown as absolute counts (n = 180) across the five-point agreement scale. Neutral responses are split across the central axis for visualisation. Where the neutral count is odd, the two displayed halves are rounded to whole numbers; consequently, displayed segment labels may sum to 181 although the underlying response total is 180.
The response distributions indicate that technical robustness and safety, privacy and data governance, and transparency were perceived as among the most difficult needs to fulfil. Human agency and oversight and accountability also attracted relatively high levels of agreement regarding their difficulty. By contrast, scalability, interoperability and interconnectivity, and increased accuracy were perceived as relatively less difficult to achieve, although the response distributions indicate that these requirements remain non-trivial.
This pattern is important because the needs perceived as most difficult are concentrated at the intersection of technical system performance, governance, and organisational implementation. Technical robustness and safety require dependable behaviour under real operating conditions, while privacy and data governance involve decisions concerning data collection, access, storage, and use. Transparency similarly requires that system behaviour and decisions can be understood and appropriately communicated to relevant users and stakeholders.
The findings therefore reinforce the inclusion of ethical and governance dimensions in the baseline framework. If technical robustness and safety, privacy and data governance, and transparency are perceived as comparatively difficult to achieve, they should not be treated as late-stage compliance checks. Rather, they need to be considered from the outset in system architecture, data-management practices, human–robot interfaces, monitoring procedures and deployment governance (Floridi et al., 2022).
3.5 Perceived reliability of AI-powered robotic systems
Respondents were asked to compare the perceived reliability of AI-powered robotic systems with that of classical engineering-based approaches. Responses were analysed overall and across the three stakeholder groups to examine whether perceptions differed between managers, researchers/engineers and operators/workers.
Figure 4 presents the overall and stakeholder-group distributions.
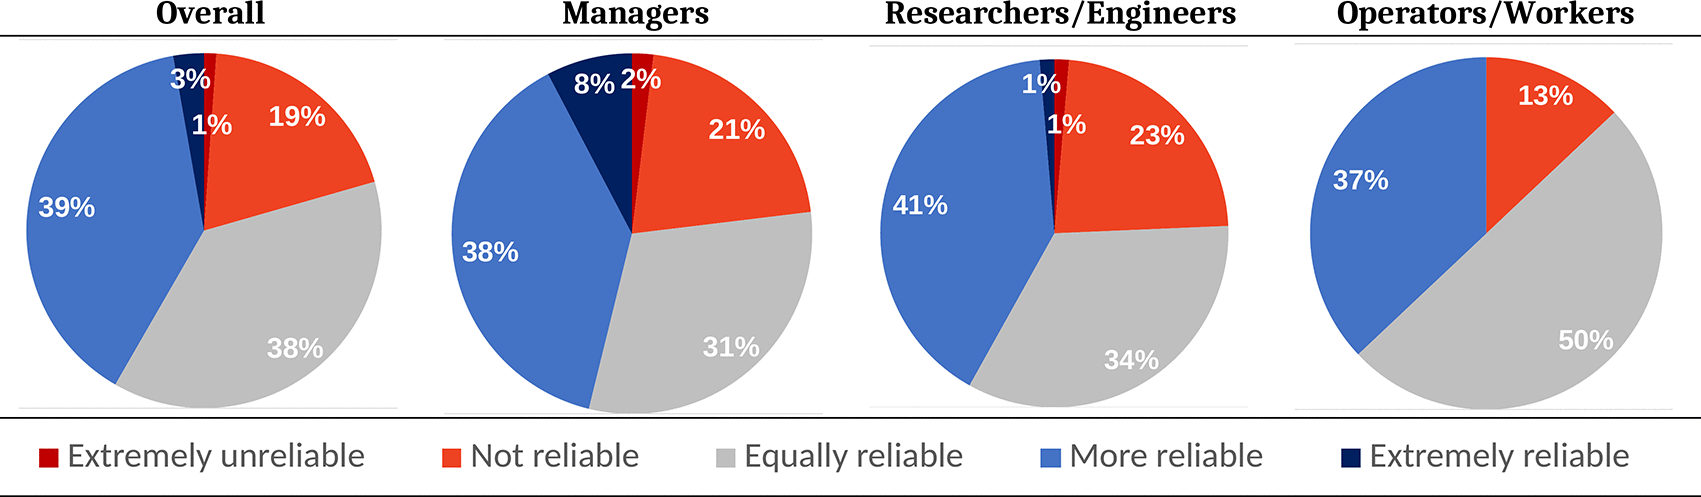
Figure 4. Perceived reliability of AI-powered versus classical engineering solutions by stakeholder group.
The results indicate a generally positive but not unconditional attitude towards the reliability of AI-powered systems. A substantial share of respondents considered AI-powered systems equally reliable or more reliable than classical engineering solutions, while managers showed the highest level of optimism. Operators/workers were comparatively more cautious and more likely to rate AI-powered and engineering-based solutions as equally reliable rather than clearly favouring AI.
This pattern supports a balanced interpretation. Stakeholders do not appear to reject AI-powered robotics, but neither do they assume that the incorporation of AI automatically improves reliability. Perceptions of AI reliability therefore appear to vary across stakeholder roles. Managers may place greater emphasis on strategic and performance potential, whereas operators/workers may require evidence from direct operational experience, safety demonstrations and transparent failure-handling procedures before developing comparable levels of confidence (Evjemo et al., 2020; Othman & Yang, 2023).
3.6 Expected positive impacts of versatile robotics
Respondents were asked to assess the expected positive impact of versatile robotics across five employment- and work-related outcomes: total job count, higher-income jobs, job satisfaction, work-life balance, and worker/operator health and safety. Responses were examined both overall and by stakeholder group, as presented in
Figure 5.
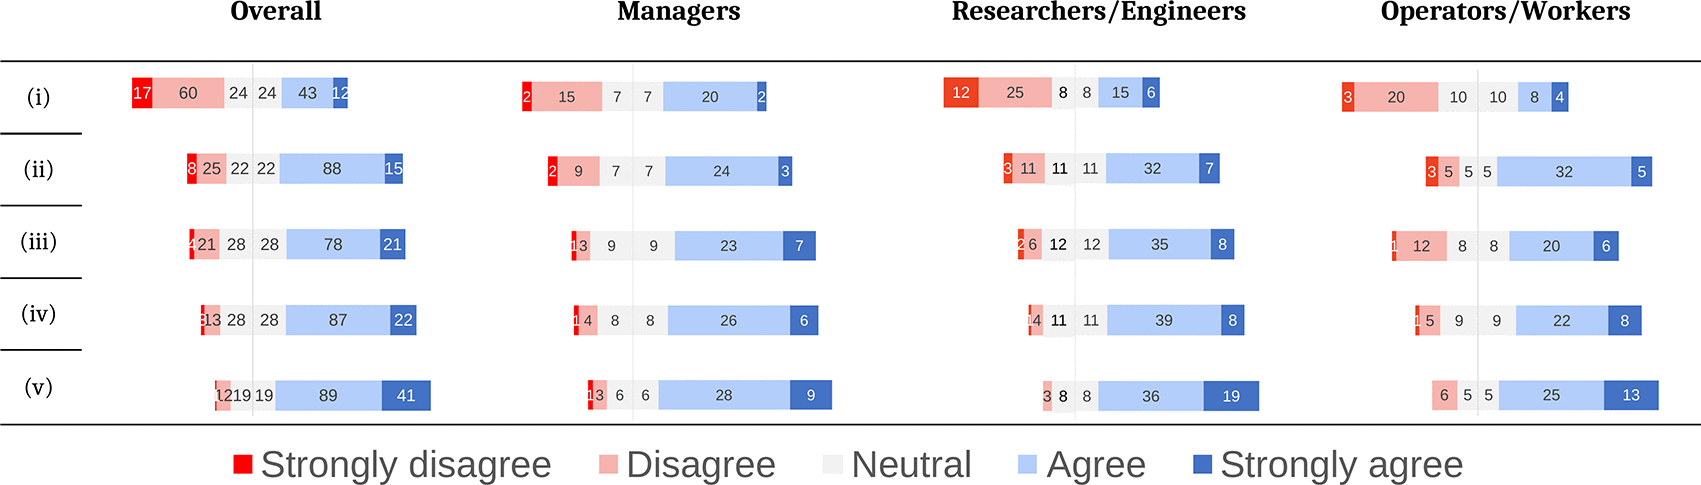
Figure 5. Expected positive impacts of versatile robotics by stakeholder group.
The assessed outcomes comprise (i) total job count; (ii) higher-income jobs; (iii) job satisfaction; (iv) work-life balance; and (v) worker/operator health and safety.
The results show that the strongest positive expectation concerned worker/operator health and safety, followed by work-life balance and higher-income jobs. Expectations regarding the effect on total job count were more cautious. This distinction suggests that respondents differentiated between the potential of robotics to improve the quality and conditions of work and its potential to generate net employment growth.
The interpretation is relevant for both deployment planning and industrial communication. Versatile robotics should therefore not be framed exclusively through productivity and efficiency narratives. An important pathway to positive stakeholder acceptance is likely to involve demonstrable improvements in safety, ergonomics, workload and overall quality of work. At the same time, claims concerning net job creation should be made cautiously unless supported by deployment-specific employment evidence (Brèque et al., 2021; Dhanda et al., 2025).
3.7 Potential opposition factors among operators/workers
Respondents were asked to assess a series of factors that could contribute to opposition or resistance to versatile robotics among operators/workers. The assessed factors covered physical safety, privacy, reliability, training requirements, workplace monitoring, professional value, changes in work routines or roles, and job security.
Figure 6 presents the response distributions for these opposition factors across stakeholder groups.
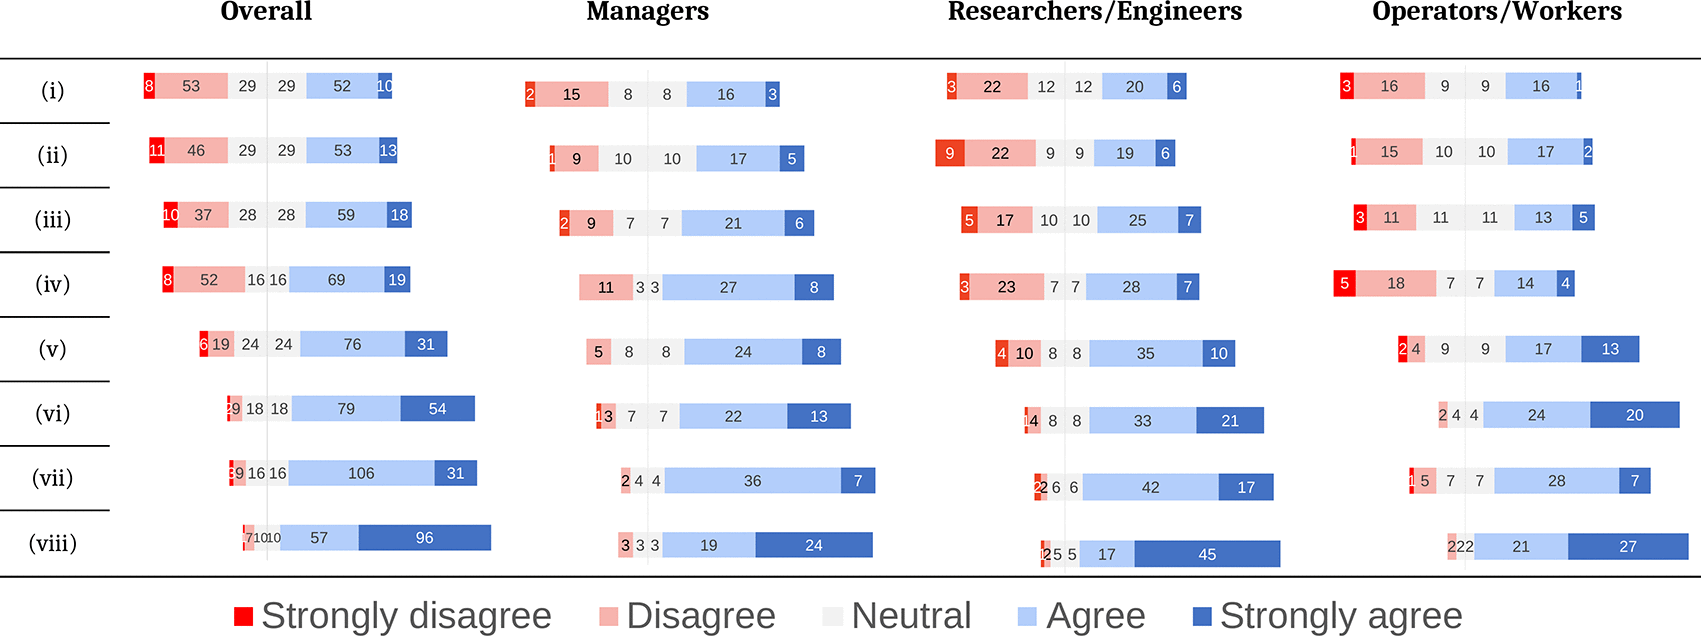
Figure 6. Stakeholder assessments of potential reasons for operators’/workers’ resistance to versatile robotics.
Responses are shown overall and by stakeholder group across the five-point agreement scale. The assessed potential reasons for operators’/workers’ resistance comprise: (i) fear of being injured by the robot; (ii) fear of privacy violation; (iii) concerns about the robot’s reliability; (iv) need for additional training; (v) fear of being constantly evaluated; (vi) fear of having one’s value diminished; (vii) potential change in routine or role; and (viii) fear of losing one’s job.
These results indicate that potential opposition was most strongly associated with job-security and role-identity concerns. Fear of losing one’s job, potential changes in routine or role, and fear of having one’s professional value diminished emerged as particularly salient resistance factors. Concerns regarding physical injury, privacy violation and system reliability were also present, but the strongest sources of potential opposition were predominantly socio-organisational rather than purely technical.
This finding suggests that technical performance and safety certification alone may be insufficient to secure workforce acceptance. Where concerns about job displacement, changing responsibilities and professional value are prominent, communication focused only on accuracy, sensors, safety zones or system performance may be insufficient. Deployment strategies should explicitly address how workers will be affected, how roles are expected to evolve, what training and reskilling opportunities will be provided, and how human expertise will continue to be recognised and utilised. The result therefore provides a direct justification for incorporating workforce-retention strategies and participatory change management into robotic deployment plans (Brèque et al., 2021; Dhanda et al., 2025; Passalacqua et al., 2025).
3.8 Stakeholder-supported measures for acceptance and trust
Respondents were also asked to assess several organisational and communication measures that could facilitate acceptance of and trust in versatile robotics. These measures addressed data-use guarantees, information provision, organisational culture, workforce retention, training and communication of operational changes.
Figure 7 presents the response distributions for these acceptance and trust measures across stakeholder groups.
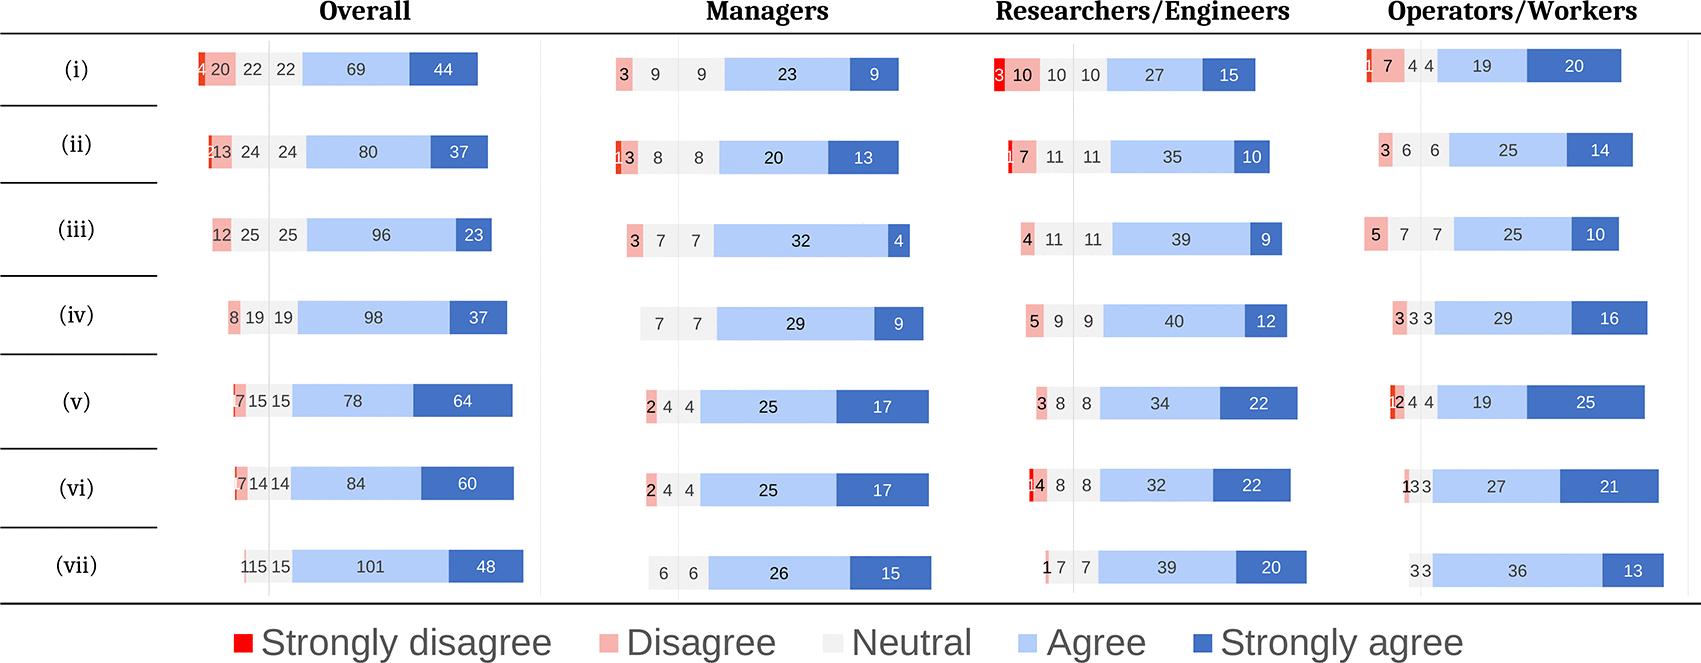
Figure 7. Stakeholder perspectives on methods for achieving acceptance and trust in versatile robotics.
Proposed methods for achieving acceptance of versatile robotics: (i) guarantees that collected data are solely used for enabling the robot to perform its tasks; (ii) providing a comprehensive briefing on the scope of robotics implementation; (iii) establishing a respectful and empathetic company culture; (iv) offering a detailed briefing on the required information; (v) presenting a plan to retain the entire workforce; (vi) implementing educational and training programmes; and (vii) clearly communicating the operational changes involved.
All proposed acceptance measures received majority support when positive responses (“Agree” and “Strongly agree”) were considered together. The highest levels of combined positive agreement were observed for clearly communicating the operational changes involved, implementing education and training programmes, presenting a plan for maintaining the workforce, and providing a comprehensive briefing on the scope of the technology introduction. Data-use guarantees and the other proposed measures also received majority support. Support for a respectful and empathetic organisational culture further suggests that respondents considered the perceived fairness of the implementation process relevant to acceptance, alongside formal safeguards and communication measures.
These findings suggest that the adoption of versatile robotics should be managed as an organisational transition rather than solely as a technology deployment. Training, transparency, workforce planning and data-use guarantees should not be regarded as peripheral communication activities; the survey results indicate that stakeholders perceive them as relevant measures for supporting acceptance and addressing potential adoption risks. For research projects, such measures should therefore be integrated into pilot design and implementation planning. For industrial adopters, they should form part of the deployment roadmap and associated business case (Kumar et al., 2021; Othman & Yang, 2023).
4. Discussion
This study supports treating AI-powered versatile robotics for agile production as a sociotechnical system. The discussion below synthesises the baseline frameworks presented in
Table 3 with the empirical patterns shown in
Figures 2–7. The core technical priorities identified by stakeholders - reliability, maintainability, increased accuracy, and adaptability - are consistent with the operational realities of manufacturing. However, the results also highlight ethical governance, workforce acceptance and organisational readiness as important conditions to consider alongside technical performance in industrial adoption. This is the principal analytical contribution of the paper: it connects technical robotics requirements with human-centred and governance-related conditions in a single triangulated framework (Michalec et al., 2021; Brèque et al., 2021; Passalacqua et al., 2025).
4.1 Technical performance as an adoption prerequisite
Reliability and maintainability received high importance because they directly affect production continuity. In agile manufacturing, reconfiguration and adaptability are valuable only if the robotic system can sustain dependable performance across product variants and operating conditions. A robot that is technically versatile but unreliable creates production risk rather than agility. Similarly, high accuracy is particularly important in assembly, gluing, deburring, insertion and manipulation tasks where small deviations can create quality defects or rework (Sanneman et al., 2021; Arents & Greitans, 2022; Sun et al., 2023).
These findings suggest that research and innovation projects should avoid overstating autonomy as the sole benchmark of progress. For industrial stakeholders, autonomy is meaningful when it is embedded in robust, maintainable and verifiable behaviour. Demonstrations should therefore measure not only whether a task can be performed, but also repeatability, recovery from errors, integration burden, maintenance requirements, operator workload and safety performance under realistic conditions (Sanneman et al., 2021).
4.2 Ethical requirements as operational requirements
The study shows that ethical requirements are operationally consequential. Privacy and data governance are relevant to workers’ acceptance of sensing technologies such as cameras and biometric devices. Transparency is relevant to operators’ understanding of and trust in robot behaviour. Human agency and oversight are associated with issues of perceived control and accountability. Diversity, non-discrimination and fairness are relevant to ensuring that AI-enabled robotics is inclusive across different users, worker profiles and workplace conditions (Hickman & Petrin, 2021).
The fact that technical robustness and safety, privacy and data governance, and transparency were perceived as difficult to meet indicates that these issues require concrete design decisions. Examples include minimising personal-data capture, defining data-retention limits, separating operational data from worker-evaluation data, providing user-facing explanations, documenting failure modes, maintaining human override mechanisms and ensuring cybersecurity-by-design. Ethical requirements should therefore be translated into engineering and organisational controls (Floridi et al., 2022).
4.3 Workforce acceptance and the limits of productivity-centred narratives
The results indicate that potential workforce resistance is most strongly associated with perceived consequences for employment, role stability and human value. Fear of job loss and fear of diminished value should therefore not be treated simply as obstacles to be overcome through communication; they represent substantive workforce concerns that deployment strategies need to address. This finding is consistent with the broader literature on digital transformation, where employee resistance, skills gaps, trust deficits and cyber-physical safety concerns often determine implementation outcomes (Evjemo et al., 2020; Brèque et al., 2021; Dhanda et al., 2025; Passalacqua et al., 2025).
A deployment strategy focused only on productivity, cost reduction and competitiveness may therefore be insufficient to address workforce resistance, even when the technology is technically sound. A more credible strategy is to frame versatile robotics as a means to remove hazardous, repetitive or ergonomically difficult work while reskilling workers for supervision, programming, maintenance, quality control and exception handling. This framing must be backed by concrete workforce-retention and training commitments, otherwise it risks being perceived as unsupported reassurance (Brèque et al., 2021; Ibarguren et al., 2025).
4.4 Implications for system designers and integrators
The adoption-factor results further show that versatile robotics is evaluated through both technical feasibility and organisational-economic considerations. Increased productivity, cost reduction, competitiveness and return on investment were among the strongest drivers, whereas investment and maintenance costs represented the most prominent barrier. The high ranking of IT systems and ease of use as enablers further indicates that successful adoption depends not only on robotic capability but also on integration readiness and usability.
For system designers, the results imply that explainability, usability and maintainability should be treated as first-order design objectives. Interfaces should present robot status, task progress, confidence indicators, failure explanations and required human interventions in a way that is understandable for operators, not only for engineers. Systems should also be designed for integration with legacy industrial infrastructure, since interoperability remains a practical condition for adoption in existing factories (Sanneman et al., 2021; Othman & Yang, 2023).
For integrators, the findings underline the need to build deployment roadmaps that include organisational readiness assessment, pilot validation, worker training, data-governance procedures, safety validation and post-deployment monitoring. The business case should include not only productivity gains but also implementation costs, maintenance requirements, training burden, risk reduction and expected effects on quality and worker well-being (Kumar et al., 2021; Dhanda et al., 2025).
4.5 Implications for policymakers and research funding
For policymakers and research funders, the study supports the coupling of robotics innovation with workforce transition measures, industrial standards and trustworthy AI guidance. Funding schemes should encourage not only technical performance metrics but also evidence on training, acceptance, data governance, human oversight, maintainability and post-deployment monitoring.
The AGIMUS baseline framework can therefore support both project-level development and policy-level monitoring. It helps identify whether an emerging robotics solution is progressing only technologically or whether it is also addressing the adoption conditions required for responsible industrial deployment.
4.6 Temporal validity and implications of using a 2023 survey dataset
The age of the survey data is not a minor methodological detail. The survey was implemented in March 2023, while the manuscript is being prepared for publication more than three years later. Since then, the external environment has evolved significantly. The adoption of the EU Artificial Intelligence Act (AI Act) in 2024 established a binding, risk-based regulatory framework for AI and made issues such as AI-system classification, documentation, transparency and human oversight increasingly explicit compliance considerations, with the associated obligations becoming applicable progressively according to the Act’s implementation timeline (
European Union, 2024). ISO/IEC 42001:2023 (ISO, 2023) provided a management-system framework for organisations developing or using AI, while the updated ISO 10218-1:2025 (ISO, 2025) standard reflects the continuing evolution of industrial robot safety requirements. At the same time, recent Industry 5.0 and human-robot collaboration literature increasingly frames worker well-being, human-centric design, personalisation and trustworthy AI as core industrial adoption criteria rather than secondary ethical topics (Ahangar et al., 2025; Bucci et al., 2025; Dhanda et al., 2025; Ibarguren et al., 2025; Passalacqua et al., 2025).
These developments have two implications for this paper. First, some survey findings are likely to be even more relevant today than when the data were collected. In particular, the post-2023 regulatory and standardisation environment reinforces the relevance of the ethical, governance and technical-robustness dimensions identified in the framework (Ahangar et al., 2025). Second, the data should not be over-claimed as a current measurement of 2026 attitudes. Stakeholder perceptions may have shifted due to broader exposure to generative AI, increased debate on AI regulation, faster diffusion of industrial automation and changing labour-market concerns. Therefore, the results should be read as a baseline against which future surveys can be compared.
This temporal framing strengthens rather than weakens the contribution, provided it is interpreted correctly. The survey captures stakeholder expectations before the latest regulatory consolidation and before the current wave of AI-enabled interaction technologies became mainstream in manufacturing debates. As such, the dataset offers a useful reference point for longitudinal analysis: if similar concerns continue to appear in updated surveys, they can be interpreted as persistent adoption barriers rather than transient perceptions. Conversely, where future data diverge from the 2023 baseline, the differences may reveal how regulation, market maturity and industrial experience have reshaped robotics adoption priorities.
4.7 Limitations
Several limitations must be acknowledged. First, the survey sample is European and multi-country, but it is not statistically representative of the full European manufacturing sector. Poland is overrepresented relative to some other countries, and the sample structure reflects the availability and screening logic of the online recruitment platform (Palan & Schitter, 2018; Peer et al., 2022). Second, the quantitative data were collected in March 2023 and are therefore approximately three years old at the point of manuscript finalisation. This temporal distance is important because AI regulation, standardisation, generative AI applications and industrial robotics adoption have evolved rapidly since data collection. The results should consequently be interpreted as a baseline dataset rather than as a current market measurement. Third, the study is based on stakeholder perceptions and exploratory industrial case-study evidence rather than long-term performance monitoring of fully deployed robotic systems. Fourth, the case studies are connected to the AGIMUS project and therefore cannot cover all sectors, company sizes or manufacturing contexts. Fifth, the study reports descriptive and weighted-mean analyses; it does not claim causal inference or statistically generalisable sector-wide estimates. Future work should repeat the survey with an updated sample, incorporate longitudinal pilot evidence and compare whether stakeholder priorities have changed as the phased implementation of the EU AI Act progresses and updated robotics safety standards are adopted in industrial practice.
5. Conclusions
This paper presented an interdisciplinary sociotechnical analysis of AI-powered versatile robotics for agile production. By combining desk research, expert interviews, industrial case-study analysis and a stakeholder survey of 180 respondents from 16 European countries, the study identified, refined and triangulated the principal technical, ethical and organisational conditions relevant to adoption.
The results show that stakeholders prioritise reliability, maintainability, increased accuracy and adaptability as core technical requirements. They also perceive technical robustness and safety, privacy and data governance, and transparency as difficult but essential conditions. Among the broader adoption factors, increased productivity, cost reduction, competitiveness and return on investment emerged as prominent drivers; investment and maintenance costs represented the most prominent barrier; technology acceptance and human-robot collaboration were the highest-rated challenges; and IT systems and ease of use ranked highly among the enablers. Potential workforce resistance was associated mainly with job-security, role-change and value-recognition concerns, while clear communication of operational changes, educational and training programmes, workforce-retention plans and comprehensive briefing on the scope of implementation received the strongest stakeholder support as measures for facilitating acceptance.
The resulting triangulated framework provides a practical basis for researchers, manufacturers, integrators and policymakers to assess whether robotics deployment plans address technical, ethical, organisational and workforce-related requirements. Given that the survey data were collected in 2023, the findings also provide a longitudinal reference point against which future studies can examine whether these priorities and acceptance concerns persist under evolving regulatory and technological conditions (Ahangar et al., 2025; Dhanda et al., 2025).
Ethics and consent
Ethical approval was not required for the present study because Greek legislation does not provide for an ethics approval procedure for this type of research, as clarified by the Hellenic National Commission for Bioethics and Technoethics. Accordingly, no ethical approval, permit or reference number was issued. The research followed the provisions described in the AGIMUS Data Management Plan – Second Version (D8.3) to ensure the appropriate management of research data. The AGIMUS Data Management Plan was reviewed and accepted by the European Commission as a project deliverable and is publicly available at: https://www.agimus-project.eu/media/attachments/2026/03/09/d8.3_data-management-plan---second-version.pdf
Written informed consent was obtained from all interviewees prior to the interviews.
Survey participants were recruited through Prolific and voluntarily opted into the study after reviewing the study information provided through the platform. No names, personal email addresses or other direct identifiers were requested or collected by the research team, and no minors participated in the survey.







